 |
Bowls Eye
1.0
|
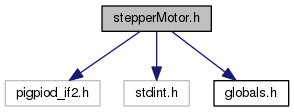
Go to the source code of this file.
Classes | |
| struct | StepperMotor_t |
| Structure for interfacing with stepper motor and its dual H bridge driver. More... | |
Functions | |
| void | StepperMotor_construct (StepperMotor_t *stepper, uint8_t multiple) |
| void | StepperMotor_enable (StepperMotor_t *stepper) |
| void | StepperMotor_update (StepperMotor_t *stepper) |
| void | StepperMotor_setDirection (StepperMotor_t *stepper, uint8_t direction) |
| void | StepperMotor_setStepSize (StepperMotor_t *stepper, uint8_t multiple) |
| void | StepperMotor_enA (StepperMotor_t *stepper) |
| void | StepperMotor_enB (StepperMotor_t *stepper) |
| void | StepperMotor_disable (StepperMotor_t *stepper) |
| void | StepperMotor_incrementStep (StepperMotor_t *stepper) |
| void | StepperMotor_decrementStep (StepperMotor_t *stepper) |
| void | StepperMotor_wrapStep (StepperMotor_t *stepper) |
| void | StepperMotor_step0 (StepperMotor_t *stepper) |
| void | StepperMotor_step1 (StepperMotor_t *stepper) |
| void | StepperMotor_step2 (StepperMotor_t *stepper) |
| void | StepperMotor_step3 (StepperMotor_t *stepper) |
Definition in file stepperMotor.h.
| void StepperMotor_construct | ( | StepperMotor_t * | stepper, |
| uint8_t | multiple | ||
| ) |
Constructor for StepperMotor_t
| stepper | Instance of StepperMotor_t |
| multiple | Multiple of minimum step angle (0.9deg), defines angular resolution of system |
Definition at line 15 of file stepperMotor.c.
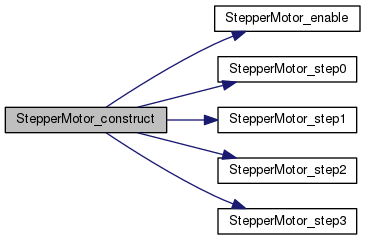
References StepperMotor_t::currentStep, StepperMotor_t::pinB1, StepperMotor_t::pinEnA, StepperMotor_t::stepMultiple, StepperMotor_enable(), StepperMotor_step0(), StepperMotor_step1(), StepperMotor_step2(), StepperMotor_step3(), and StepperMotor_t::waitTime.
| void StepperMotor_decrementStep | ( | StepperMotor_t * | stepper | ) |
Decrement the current step of the motor
| stepper | Instance of StepperMotor_t |
Definition at line 147 of file stepperMotor.c.
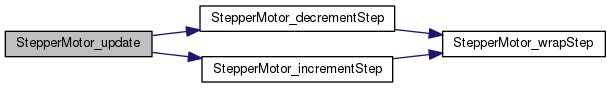
References StepperMotor_t::currentStep, and StepperMotor_wrapStep().
Referenced by StepperMotor_update().

| void StepperMotor_disable | ( | StepperMotor_t * | stepper | ) |
Disable the stepper motor
| stepper | Instance of StepperMotor_t |
Definition at line 101 of file stepperMotor.c.
References StepperMotor_t::pinB1, and StepperMotor_t::pinEnA.
| void StepperMotor_enA | ( | StepperMotor_t * | stepper | ) |
Enable the A H bridge of the stepper motor driver
| stepper |
Definition at line 116 of file stepperMotor.c.
References StepperMotor_t::pinEnA.
| void StepperMotor_enable | ( | StepperMotor_t * | stepper | ) |
Enable the stepper motor
| stepper | Instance of StepperMotor_t |
Definition at line 86 of file stepperMotor.c.
References StepperMotor_t::pinB1, and StepperMotor_t::pinEnA.
Referenced by StepperMotor_construct().
| void StepperMotor_enB | ( | StepperMotor_t * | stepper | ) |
Enable the B H bridge of the stepper motor driver
| stepper |
Definition at line 125 of file stepperMotor.c.
| void StepperMotor_incrementStep | ( | StepperMotor_t * | stepper | ) |
Increment the current step of the motor
| stepper | Instance of StepperMotor_t |
Definition at line 134 of file stepperMotor.c.
References StepperMotor_t::currentStep, and StepperMotor_wrapStep().
Referenced by StepperMotor_update().

| void StepperMotor_setDirection | ( | StepperMotor_t * | stepper, |
| uint8_t | direction | ||
| ) |
Set the rotational direction of the motor
| stepper | Instance of StepperMotor_t |
| direction | Direction to assign |
Definition at line 77 of file stepperMotor.c.
| void StepperMotor_setStepSize | ( | StepperMotor_t * | stepper, |
| uint8_t | multiple | ||
| ) |
Set the size of the motor step increment, defines the angular resolution of the system
| stepper | Instance of StepperMotor_t |
| multiple | Multiple of minimum step increment (0.9deg) |
Definition at line 67 of file stepperMotor.c.
References StepperMotor_t::stepMultiple.
| void StepperMotor_step0 | ( | StepperMotor_t * | stepper | ) |
Method for performing a step
| stepper | Instance of StepperMotor_t |
Definition at line 174 of file stepperMotor.c.
References StepperMotor_t::pinB1.
Referenced by StepperMotor_construct().
| void StepperMotor_step1 | ( | StepperMotor_t * | stepper | ) |
Method for performing a step
| stepper | Instance of StepperMotor_t |
Definition at line 186 of file stepperMotor.c.
References StepperMotor_t::pinB1.
Referenced by StepperMotor_construct().
| void StepperMotor_step2 | ( | StepperMotor_t * | stepper | ) |
Method for performing a step
| stepper | Instance of StepperMotor_t |
Definition at line 198 of file stepperMotor.c.
References StepperMotor_t::pinB1.
Referenced by StepperMotor_construct().
| void StepperMotor_step3 | ( | StepperMotor_t * | stepper | ) |
Method for performing a step
| stepper | Instance of StepperMotor_t |
Definition at line 210 of file stepperMotor.c.
References StepperMotor_t::pinB1.
Referenced by StepperMotor_construct().
| void StepperMotor_update | ( | StepperMotor_t * | stepper | ) |
Update the stepper motor position
| stepper | Instance of StepperMotor_t |
Definition at line 42 of file stepperMotor.c.
References StepperMotor_t::stepMultiple, StepperMotor_decrementStep(), StepperMotor_incrementStep(), and StepperMotor_t::waitTime.
| void StepperMotor_wrapStep | ( | StepperMotor_t * | stepper | ) |
Wrap current step of motor at limits
| stepper | Instance of StepperMotor_t |
Definition at line 159 of file stepperMotor.c.
References StepperMotor_t::currentStep.
Referenced by StepperMotor_decrementStep(), and StepperMotor_incrementStep().
 1.8.11

